KH-14
- Rated torque
- 6.8–14 Nm
- Peak torque
- 70 Nm
- Approx. weight
- 0.9 kg
Kikobot Motion — KH Series
Integrated joints with a motor, harmonic reducer, encoder, drive electronics and high-speed network communication in one housing.
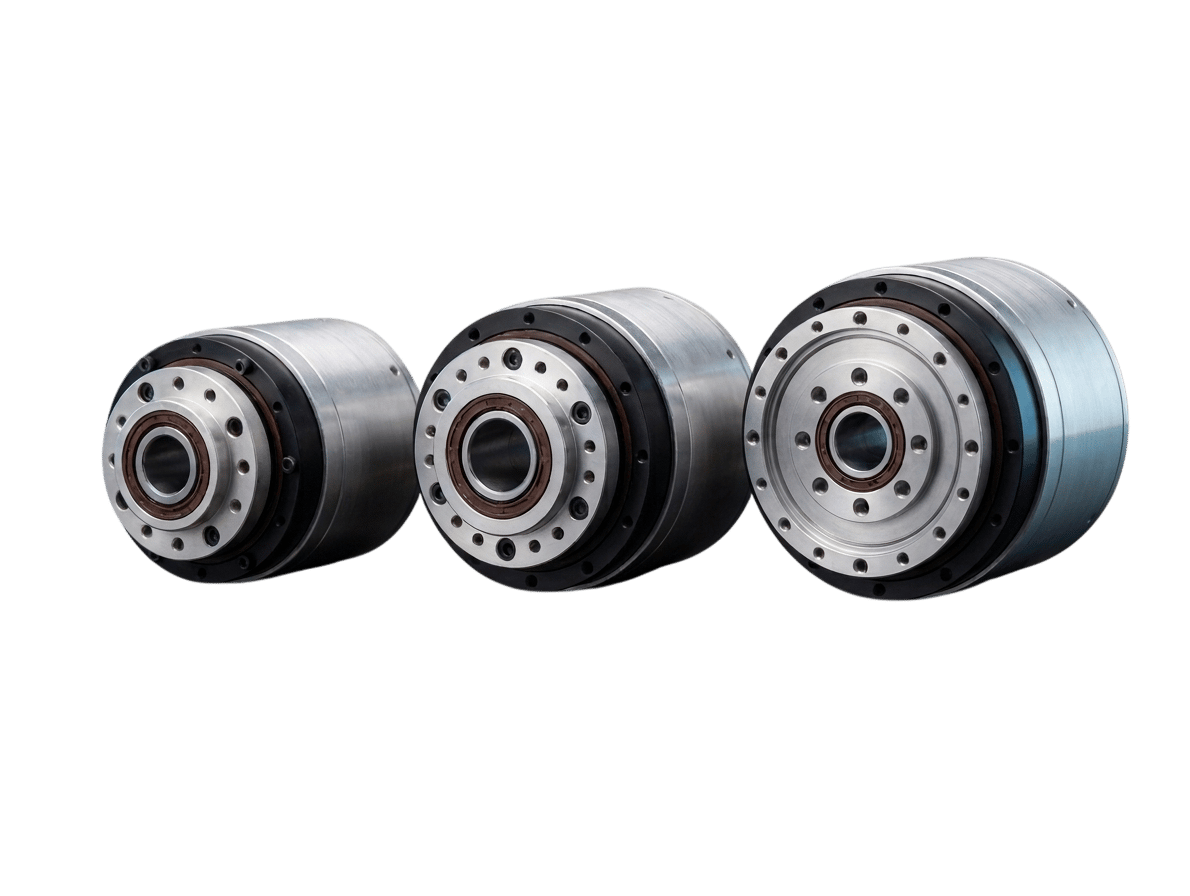
Compare models
Each size is available in three gear ratios, with or without a brake. Compare rated torque, peak torque and weight to choose a starting point for your joint.
Ratio-level selection
Use this table for initial selection. Rated and peak values are not interchangeable; peak torque is the published five-second momentary rating.
30:1
50:1
100:1
30:1
50:1
100:1
30:1
50:1
100:1
30:1
50:1
100:1
Values are typical at 25 °C ambient and are subject to change. Confirm thermal performance, external-load capacity and suitability for the complete motion profile before design-in.
How it works
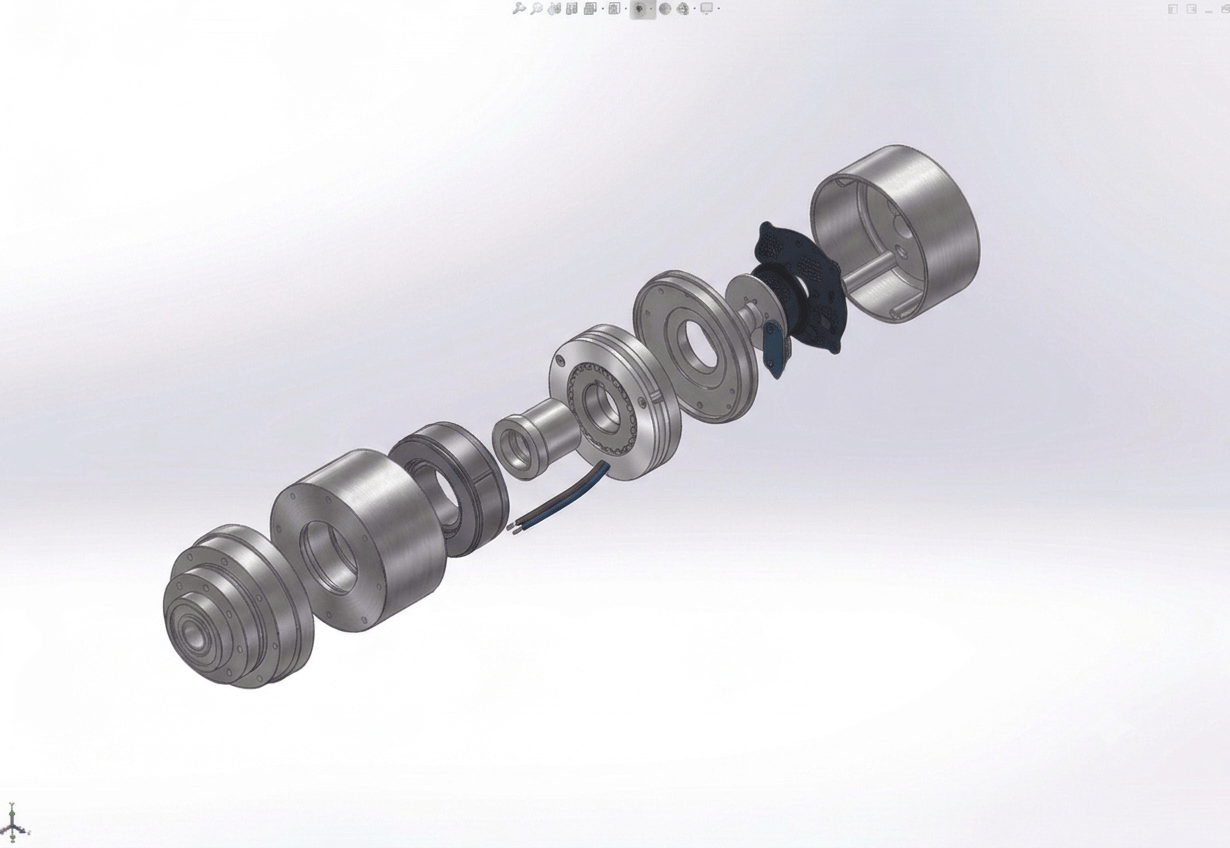
A motor, harmonic reducer, encoder and drive electronics share one housing. Bolt the finished joint to the link, run one cable, and the control loop is already closed inside the unit.
01
High torque density in a short axial stack.
02
30:1, 50:1 or 100:1 ratio, chosen per joint.
03
Absolute position held through a power cycle.
04
Current loop closed inside the joint, not in a cabinet.
05
5 Mbps daisy chain — one cable down the arm.
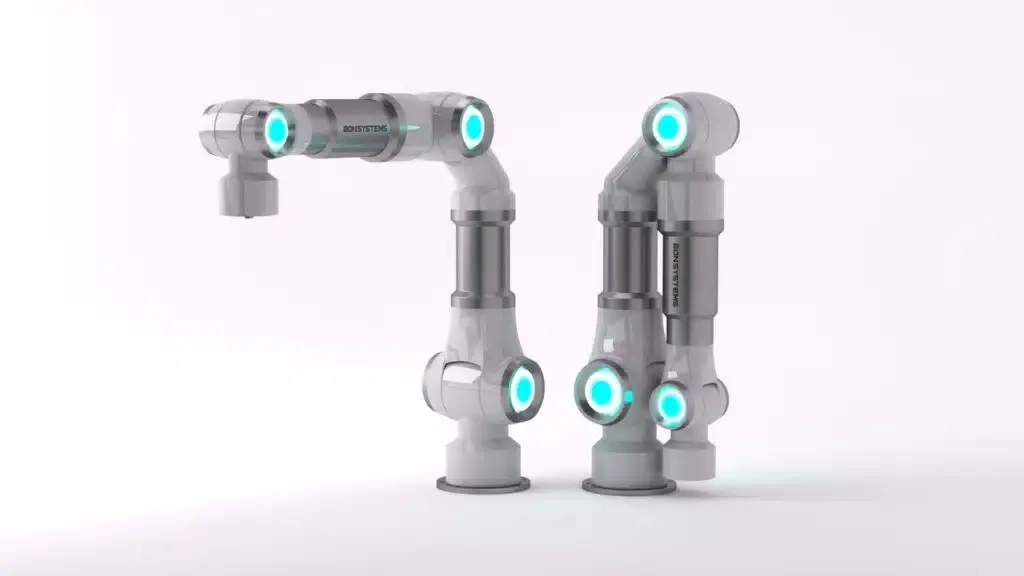
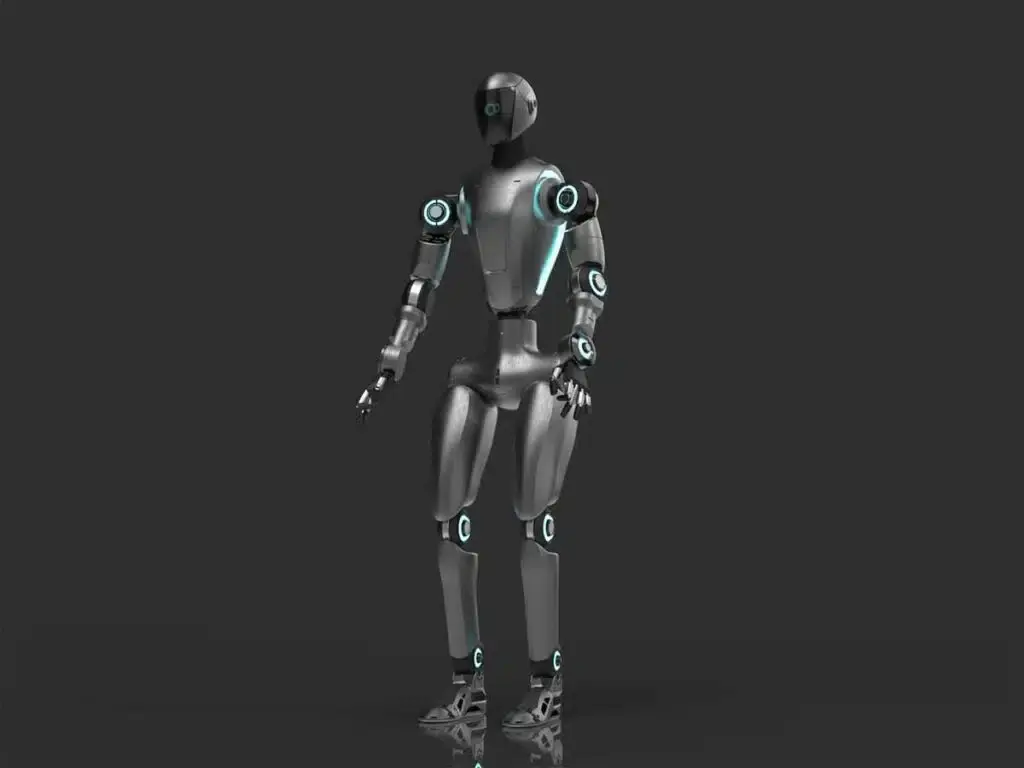
Applications
Performance evidence
The public datasheet supports initial comparison. The application evaluation closes the gap between a component rating and performance inside your machine.
The current datasheet reports typical values at 25 °C ambient. Peak torque is identified as a five-second momentary rating.
The published specification lists backlash of no more than 40 arcseconds and repeat position accuracy of ±0.01 mm across the range.
Continuous torque, thermal behaviour, external loads and life depend on the joint design and duty cycle, so they are reviewed during evaluation.
Integration resources
We identify the available public evidence separately from design-in material whose availability and revision must be confirmed with engineering.
Download
KH Series datasheet with ratio-level speed, torque, electrical, precision and weight specifications.
Confirm availability
Mechanical drawings or CAD, connector and pinout information, CAN-FD integration details and controller guidance.
Scope with engineering
Target joint load, motion profile, voltage, ratio, brake, environment, quantity and the evidence required for the decision.
The evaluation proposal confirms sample availability, current pricing, lead time, integration resources, warranty terms and the performance questions to close before design-in.
Support and deliveryFor machine builders
Share the torque, speed, voltage, ratio, brake, envelope and expected quantity. Kikobot will recommend a starting model and the relevant integration resources.