01
Motion
Integrated actuators, encoders and drive electronics turn commands into controlled movement.
Explore this layer →Physical AI
Physical AI needs more than a model. It needs motion, robot hardware, control and software that work together in the physical world. Kikobot develops those layers as one engineering stack.
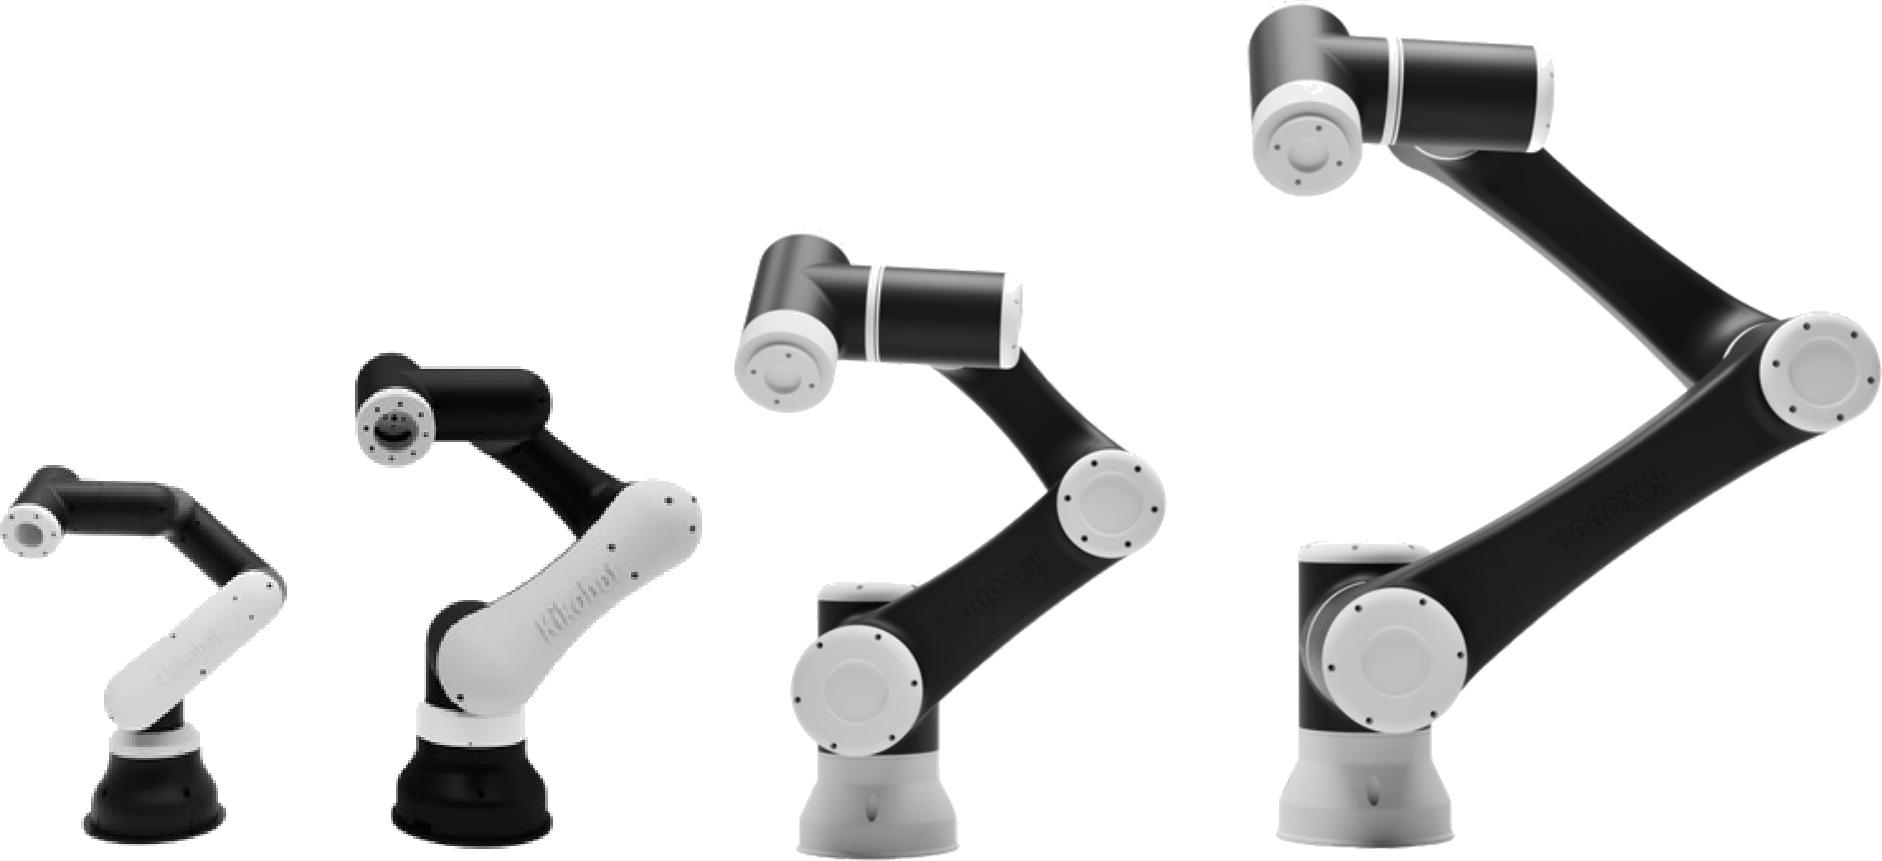
One engineering stack
Kikobot works across the physical layers that make intelligence useful: producing motion, controlling a robot, sensing the world and connecting software to a real task.
01
Integrated actuators, encoders and drive electronics turn commands into controlled movement.
Explore this layer →02
Collaborative, delta, cartesian and desktop robots provide the physical systems that act in the world.
Explore this layer →03
Control, programming, simulation and system interfaces connect motion to the intended task.
Explore this layer →04
Vision, demonstrations, datasets and learned policies let research teams develop and evaluate adaptive behavior.
Explore this layer →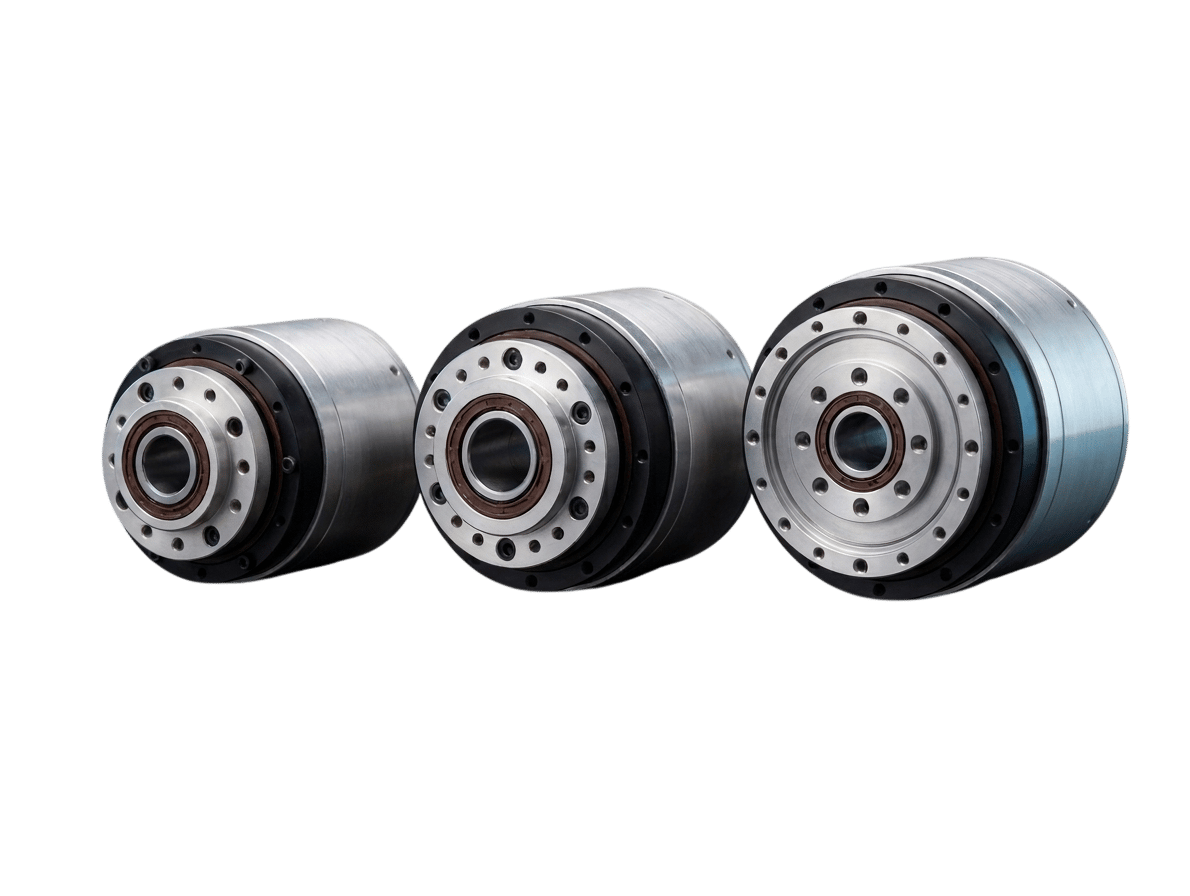
Built from the joint up
Actuators, electronics and controls determine how a robot moves, responds and exposes information to higher-level software. Developing those layers alongside robot platforms creates a direct feedback loop between component engineering and complete-system behavior.
See how Kikobot builds motion →Choose your path
For factories and integrators
Configure robot systems around a production task, part, payload, cycle and operating environment.
Explore Robotics & AutomationFor robot and machine builders
Evaluate integrated motion products for compact robot joints and machine mechanisms.
Explore MotionFor universities and R&D teams
Work with open robot platforms for teleoperation, perception, datasets, simulation and learned behavior.
Explore Research & Education